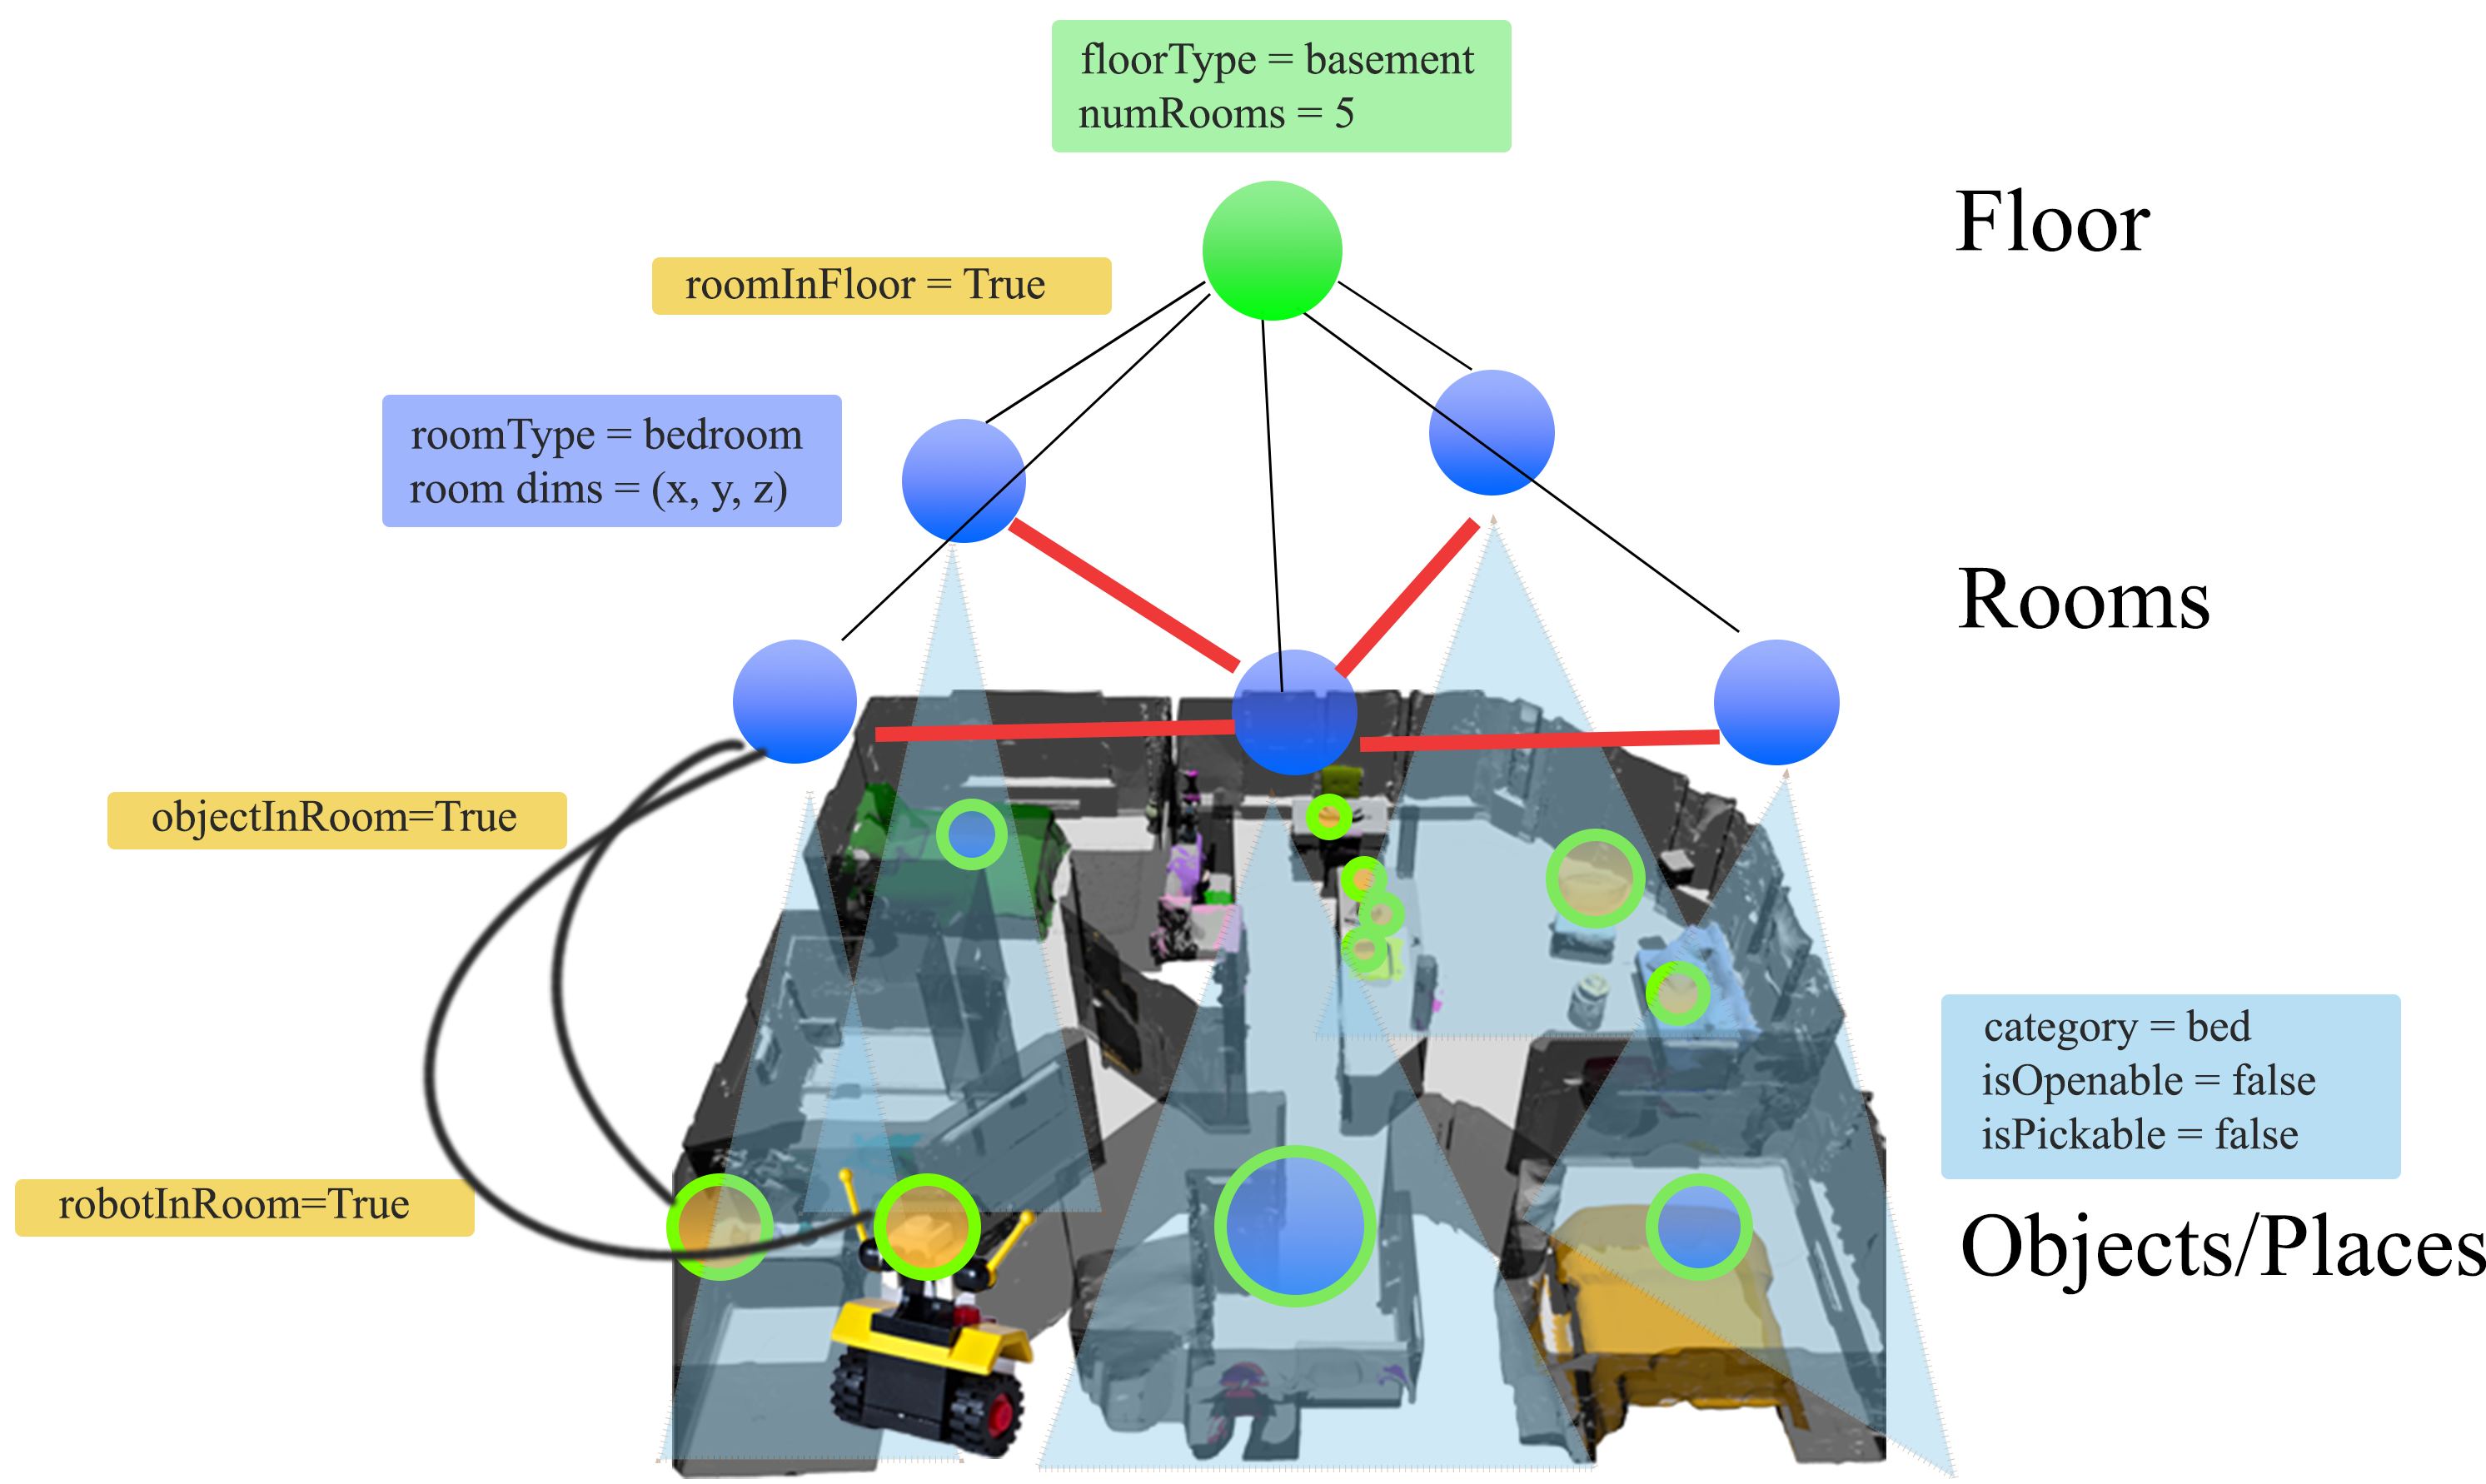
Taskography - Evaluating robot task planning over large 3D scene graphs

Taskography

People

Krishna Murthy Jatavallabhula

    Krishna Murthy Jatavallabhula


Advisor: Liam Paull    
Thesis: Differentiable world programs
Current Position: PostDoc at MIT with Antonio Torralba and Joshua Tenenbaum
Liam Paull

    Liam Paull


Interests: Robot perception, uncertainty, sim2real, and robot benchmarking

Department of Computer Science and Operations Research | Université de Montréal | Mila